Runway Ships Open-Weight Praxis-1 as Robotics Models Enter the Engineering Mainstream
The release signals how video-native AI labs are packaging embodied intelligence for researchers who need reproducible robotics stacks.
7 min read
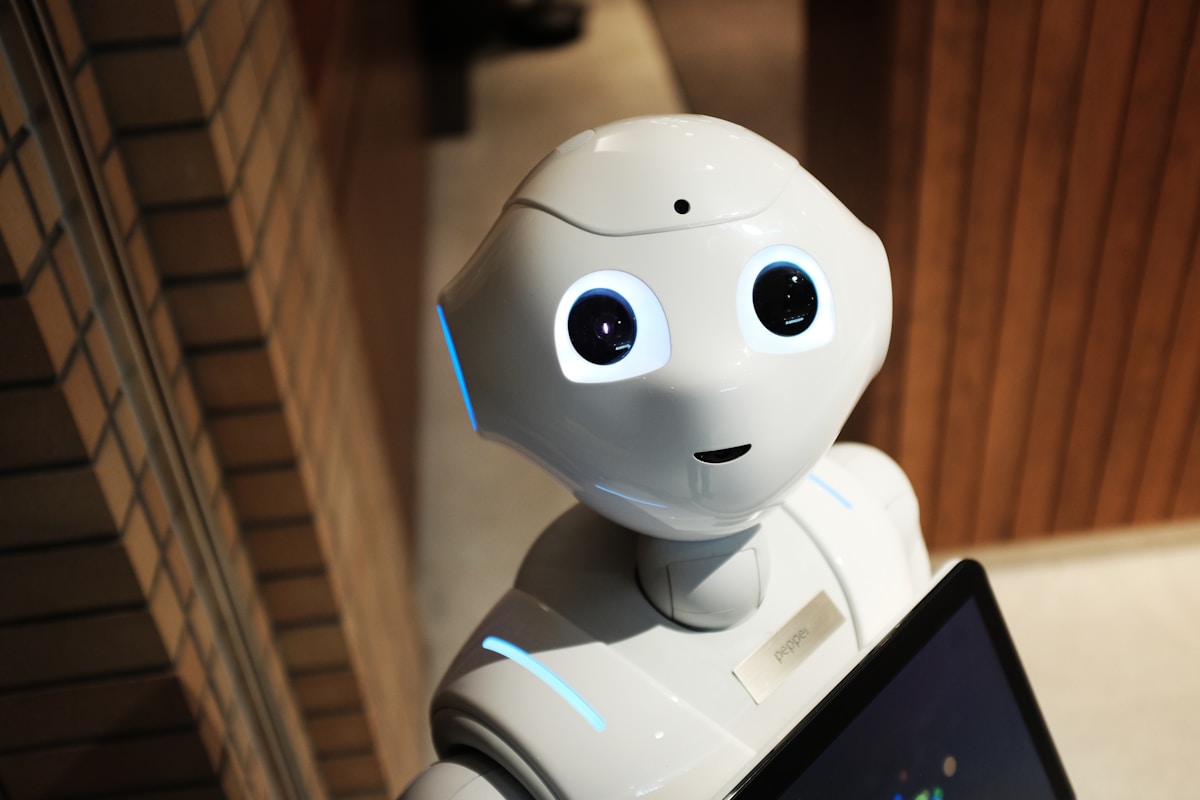
Praxis-1 and the Open-Weight Robotics Inflection
In November 2026, Runway released Praxis-1, an open-weight robotics foundation model positioned between research curiosity and deployable manipulation intelligence. Runway built its reputation on generative video and world-modeling; Praxis-1 signals a deliberate expansion into embodied AI—systems that must close the loop from perception to physical action rather than only predict pixels. For engineers and innovation leaders, the release is a datapoint in a broader trend: robotics AI is converging on multimodal transformers, simulation-first training, and license models that echo the early days of open LLMs.
What Praxis-1 Claims to Be
Public materials describe Praxis-1 as a generalist policy and dynamics model trained across diverse robot morphologies, camera placements, and task families—not a single-task grasp network frozen in 2021 pick-and-place benchmarks. Architectural details emphasize:
- Visual encoders aligned with Runway’s video priors for temporal coherence
- Action heads that emit low-level control targets or trajectory chunks compatible with common middleware (ROS 2 bridges appear in reference integrations)
- Language conditioning for task specification (“clear the table except fragile items”) with calibrated uncertainty when instructions collide with scene geometry
- Open weights with a usage license intended to permit academic and commercial fine-tuning within stated safety and attribution clauses
Praxis-1 is not a hardware stack. It does not ship motors, force-torque sensors, or safety-rated controllers. Teams still own real-time control, e-stop wiring, and compliance with local machinery directives.
Why Open Weights Matter in Robotics
Robotics historically fragmented into proprietary stacks guarded by industrial vendors and stealth startups. Open-weight releases change procurement conversations:
- Universities can reproduce baselines without NDAs blocking publication
- Integrators can fine-tune on customer scenes without shipping video to a sole cloud API
- Competitors accelerate—but so does safety research, because red teams can inspect failure modes
The downside is familiar from LLMs: misuse for unsafe automation, shallow fine-tunes on uncertified hardware, and overconfidence when a foundation model transfers poorly from simulation to a greasy factory floor.
Runway’s license choices (attribution, redistribution limits on certain derived checkpoints, prohibitions on weaponization categories) attempt to thread the needle between community adoption and liability containment. Legal teams should read the license before baking Praxis-1 into customer-facing SLAs.
Engineering Integration: From Checkpoint to Torque
A pragmatic integration path for engineering organizations looks like this:
- Hardware-in-the-loop sandbox with the same cameras and joint controllers planned for production, not only GPU workstations
- Sim fine-tune on domain randomizations (lighting, texture, calibration drift) using Runway’s published fine-tuning recipes or internal equivalents
- Latency budgeting: Praxis-1 inference may run at Hz rates sufficient for manipulation but not for sub-millisecond vibration control—separate low-level PID loops remain mandatory
- Safety interlocks that cannot be overridden by model outputs; treat network outputs as setpoints subject to clipping and watchdog timers
- Continuous evaluation on held-out real scenes weekly; robotics models drift as tools wear and humans rearrange workspaces
Teams accustomed to classical motion planning should expect behavioral policies that handle clutter but struggle on precise tolerances until fine-tuned. Hybrid architectures—planner for coarse approach, Praxis-style policy for contact-rich phases—often outperform pure end-to-end zealotry.
Innovation Angle: World Models Meet the Loading Dock
Runway’s video heritage matters technically. Policies trained with strong spatiotemporal prediction tend to anticipate occlusions and human co-presence better than static-frame grasp nets. Innovation teams can prototype:
- Semi-structured logistics: tote picking where SKUs vary but packaging classes repeat
- Lab automation: repeatable bench tasks with language retargeting between experiments
- Field service assistance: not autonomous repair, but augmented teleop where the model suggests next safe motion for human approval
Each use case should start with human-on-the-loop deployment. November 2026 releases are not ISO 10218 certificates.
Robotics AI Trends Praxis-1 Embodies
Several industry trends converge in this release:
Foundation models for control. The same scaling playbook that improved NLP is applied to action tokens, with data mixing across robots. Critics note data diversity gaps; optimists cite rapid fine-tune gains on small real datasets.
Simulation plus real co-training. Synthetic scenes reduce rarity of edge cases; real fine-tuning anchors contact physics. Vendors that own sim renderers (including video-model companies) compress iteration cycles.
Language as the universal HMI. Operators specify tasks in natural language; engineers map constraints in code. The dual interface lowers retooling cost when SKUs or layouts change.
Open vs closed competition. Closed API robotics clouds offer convenience; open weights offer custody of data and customization. Enterprise buyers increasingly ask data residency questions robots intensify because cameras capture people and proprietary layouts.
Regulatory attention. EU machinery regulation updates and US OSHA guidance on collaborative robots push documentation burdens upward. Open weights do not remove the need for risk assessments when integrators ship cells to factories.
Competitive Landscape in Late 2026
Praxis-1 enters a crowded narrative:
- Industrial incumbents embed proprietary vision on arms they sell
- Autonomous mobile robot vendors bundle narrow vertical models for warehousing
- University consortia release smaller open policies with transparent datasets
- Hyperscalers pitch robotics tokens as cloud APIs with per-minute inference billing
Runway differentiates with creative-industry brand crossover—studios and simulation-heavy digital twins—not only forklift economics. That may attract hybrid digital-physical teams (virtual production stages testing policies before physical deployment).
Risks for Engineering Leadership
Safety: Statistical policies fail on long-tail physics. Maintenance of mechanical stops and training for human coworkers outweigh model accuracy in incident prevention.
IP: Cameras recording factory floors may capture trade secrets; on-prem fine-tune of open weights reduces outbound data but increases insider governance needs.
Workforce: Automation narratives spook labor partners; change management belongs in the innovation story, not only technical milestones.
Sustainability: Inference at scale draws power; edge GPUs on each cell vs centralized batch planning affects carbon accounting customers now request.
Practical Adoption Roadmap
For a three-phase innovation program:
Phase A – Benchmark (4–8 weeks): Run published Praxis-1 checkpoints in sim on your task suite; measure success vs incumbent baselines without production traffic.
Phase B – Pilot cell (quarter): Single workstation, restricted speed, physical barriers, one operator trained on override gestures; log failures for taxonomy.
Phase C – Scale decision: Only if pilot meets OEE, injury-near-miss, and quality metrics. Negotiate support with integrators experienced in open-weight policies.
Document model version pinning. Open-weight ecosystems churn; Friday’s helpful checkpoint can be Saturday’s regression if teams auto-update.
Research and Education Ripples
Academic labs gain a new teaching vehicle: students can ablate language conditioning, compare planners, and publish negative results—healthy for the field. Negative transfers (sim policies that damage demo hardware) become cautionary labs engineering deans appreciate.
Interdisciplinary courses blending controls theory, ML, and ethics get concrete assignments: constrain Praxis outputs with control barrier functions and write the hazard analysis paragraph regulators expect.
Looking Beyond November 2026
Expect follow-on releases emphasizing bimanual coordination, mobile manipulators, and longer-horizon task graphs. Standards bodies may request model cards listing training data provenance and known sim-to-real gaps. Insurance products for AI-enabled cells will ask whether foundations like Praxis-1 were fine-tuned under documented safety cases.
Runway’s Praxis-1 is not the end of bespoke robotics software. It is an inflection toward composable intelligence: world-model priors, open weights, and language interfaces stacked atop the discipline engineering always required—limits, interlocks, and respect for the physical world’s refusal to match training distributions.
Takeaways for Builders
- Treat Praxis-1 as a starting checkpoint, not a certified controller
- Invest in hybrid planning, safety hardware, and evaluation discipline
- Use open weights when data custody and customization trump managed APIs
- Align innovation narratives with workforce and regulatory reality
The robotics AI trend is not “replace engineers with a download.” It is compress experimentation cycles for teams willing to own the last mile from tensor to torque—and to keep humans authoritative when the model’s confidence exceeds its competence.
Comments
Loading comments…